I have boundless gratitude for the sacrifices of the past generations to build the world we live in today. It is my duty to pay this forward to the next generation and make the world even better than it is now. I am dedicating my life to AI Safety because I love humanity.
I'm currently working on field-building, running a technical AI Safety course called GEAR. I'm also a software engineer at GEICO, where I work on cloud infrastructure and observability. My timelines are short and I want to work towards safety in any way I can. If you know any way I can help, be it technical research, policy work, advocacy, or field-building, please contact me.
I have technical skills as a software engineer, organizing and speaking skills as a fieldbuilder and organizer of workingtheories.nyc, and a strong work ethic.
Click the image to see each project!
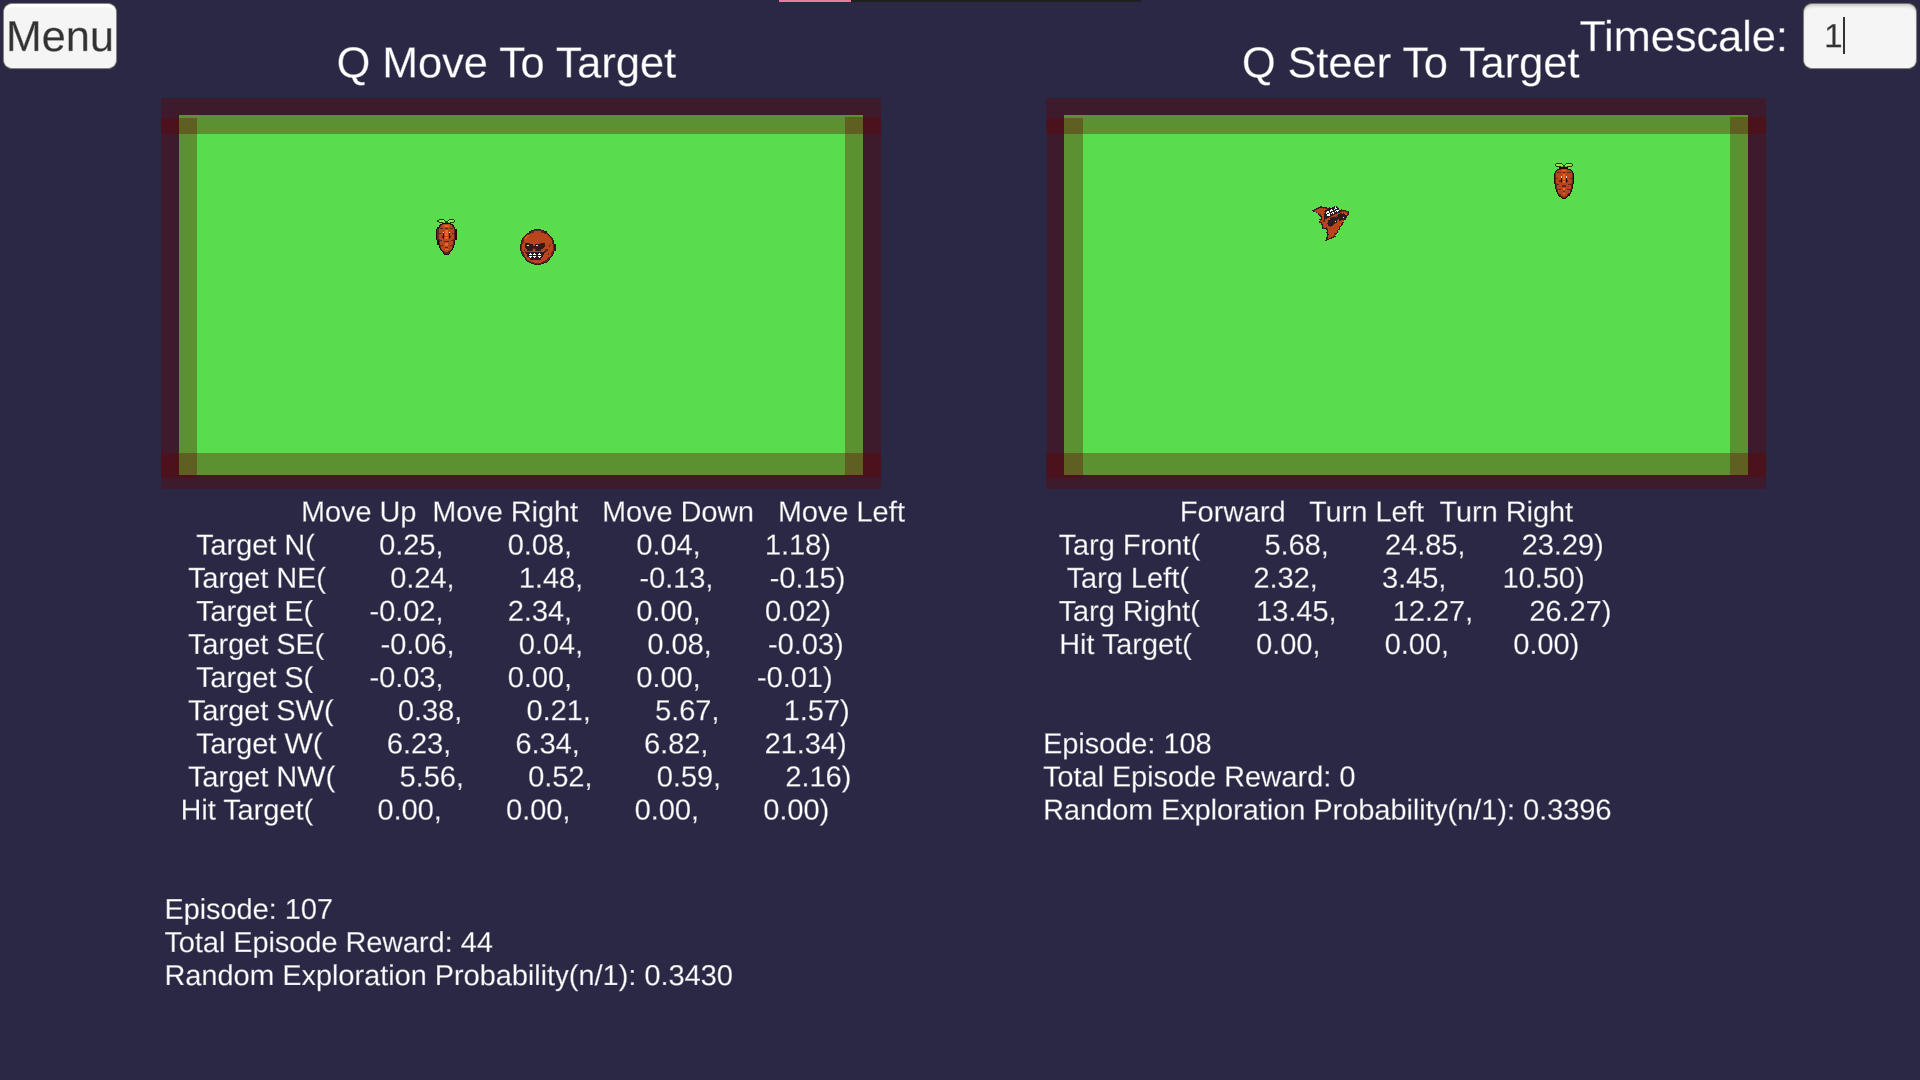
Implemented Machine Learning algorithm Q Learning from scratch in C#. Implementation is flexible and allows for customization of several settings such as number of episodes, episode length, exploration probability, exploration decay, alpha, gamma, number of states, number of actions, etc. Uses object oriented structure, where each agent inherits from a QAgent class and needs to overload GetNextState() and GetReward(). Additional optional overloads include Start(), Update(), Iterate(), OnEpisodeBegin(), and OnEpisodeEnd(). Created demo with 2 agent types and live learning (click the image to see it!).
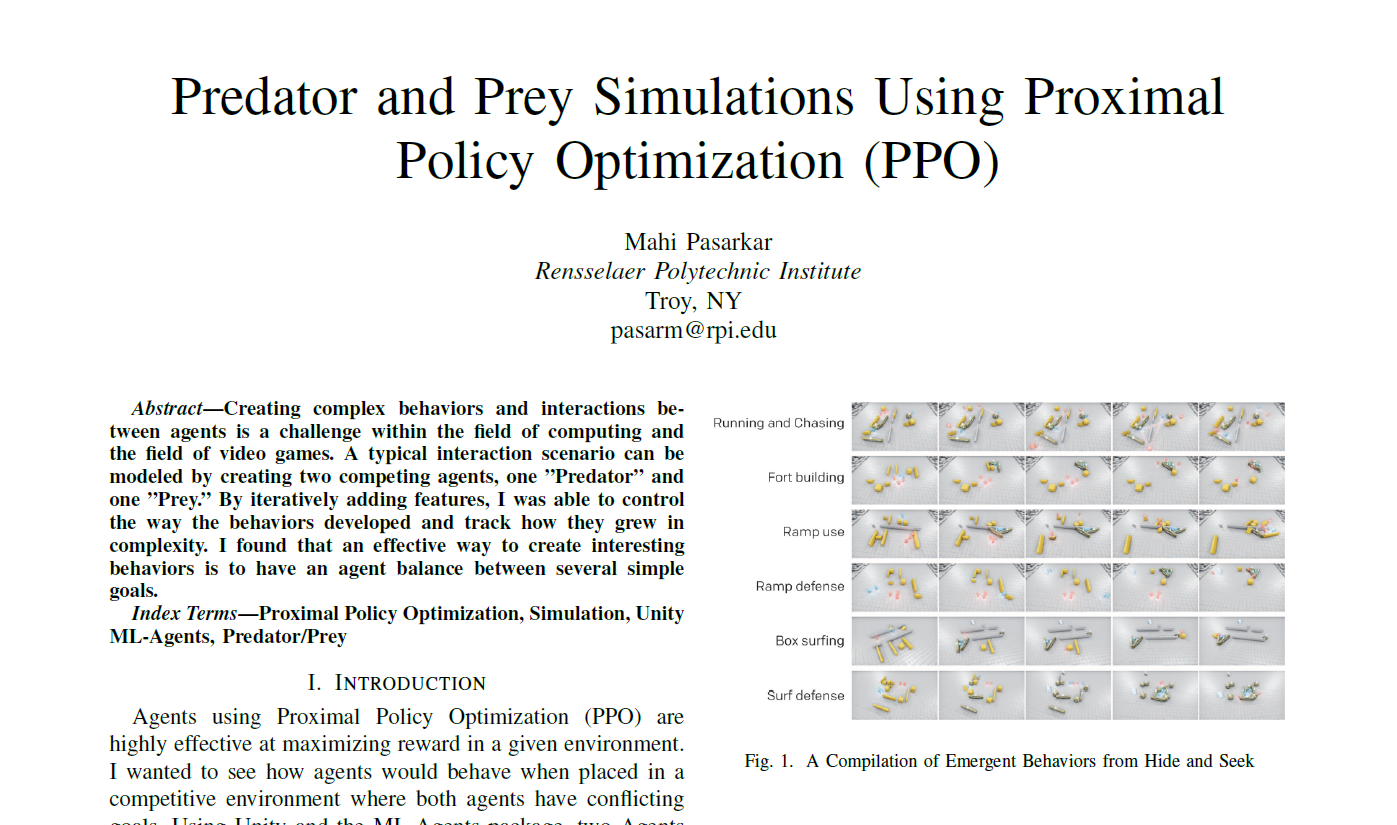
Created Predator vs Prey simulation using Proximal Policy Optimization algorithm. Both agents are in 2D space and move in all 4 directions. They collect observations for their location, the other agent's location, and 8 raycast sensors. Reward functions reward predator for "catching" the prey by colliding with it as soon as possible. For the prey, reward is higher the longer it evades the predator. Prey must also balance fleeing the prey with collecting its "food." Results of this experiment are documented in a paper linked on the Github repository (click the image to read it!).
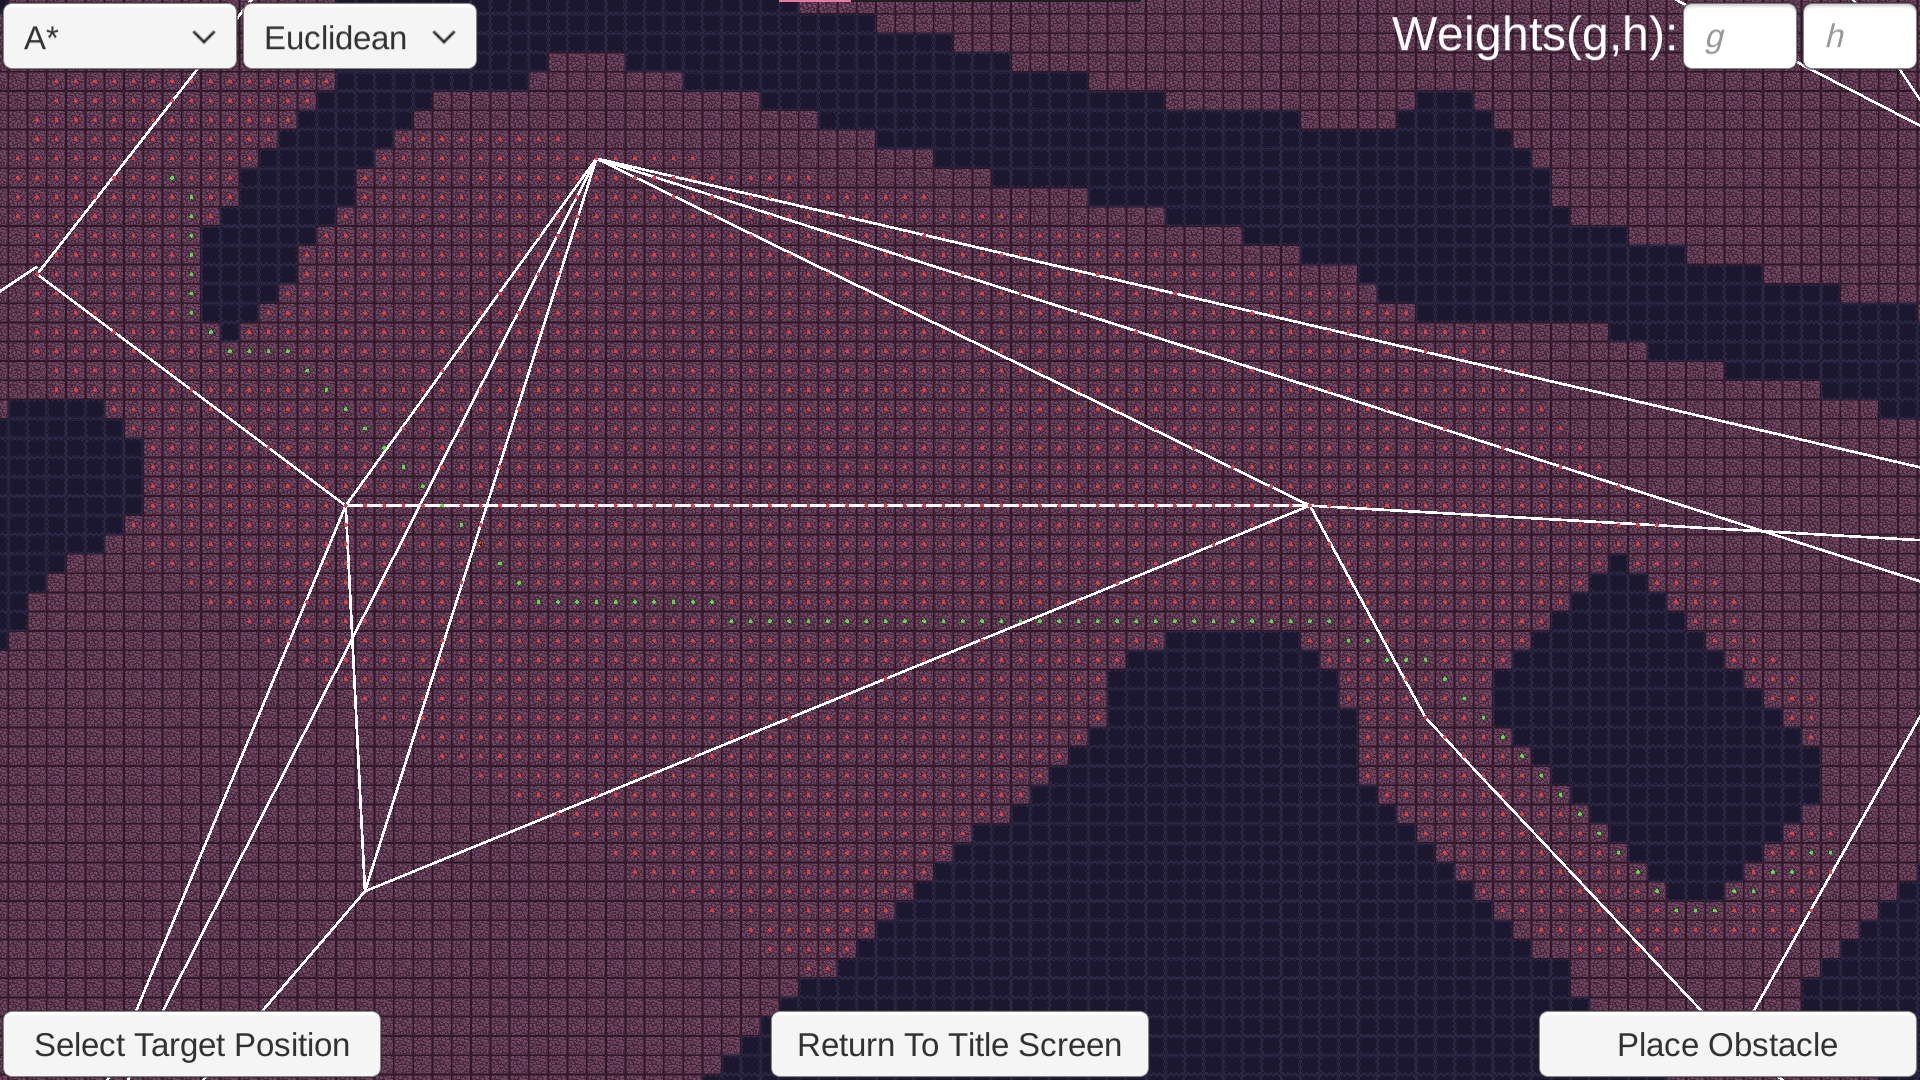
Implemented A* pathfinding algorithm for an agent in a 2D grid. Algorithm is fully customizable, with ability to change G and H weights and ability to choose between two distance heuristics (Manhattan vs Euclidean distance). Optimizations of algorithm include removing need for baking grid for a given map by creating the grid in real time during exploration. Agent will try a given direction, but will not include it if it collides with a wall. Client can place new obstacles on the path and the agent will recalculate the path in real time. The algorithm is fully visualized with red dots indicating explored areas and green dots indicating the path. (Click the image to play the demo!)
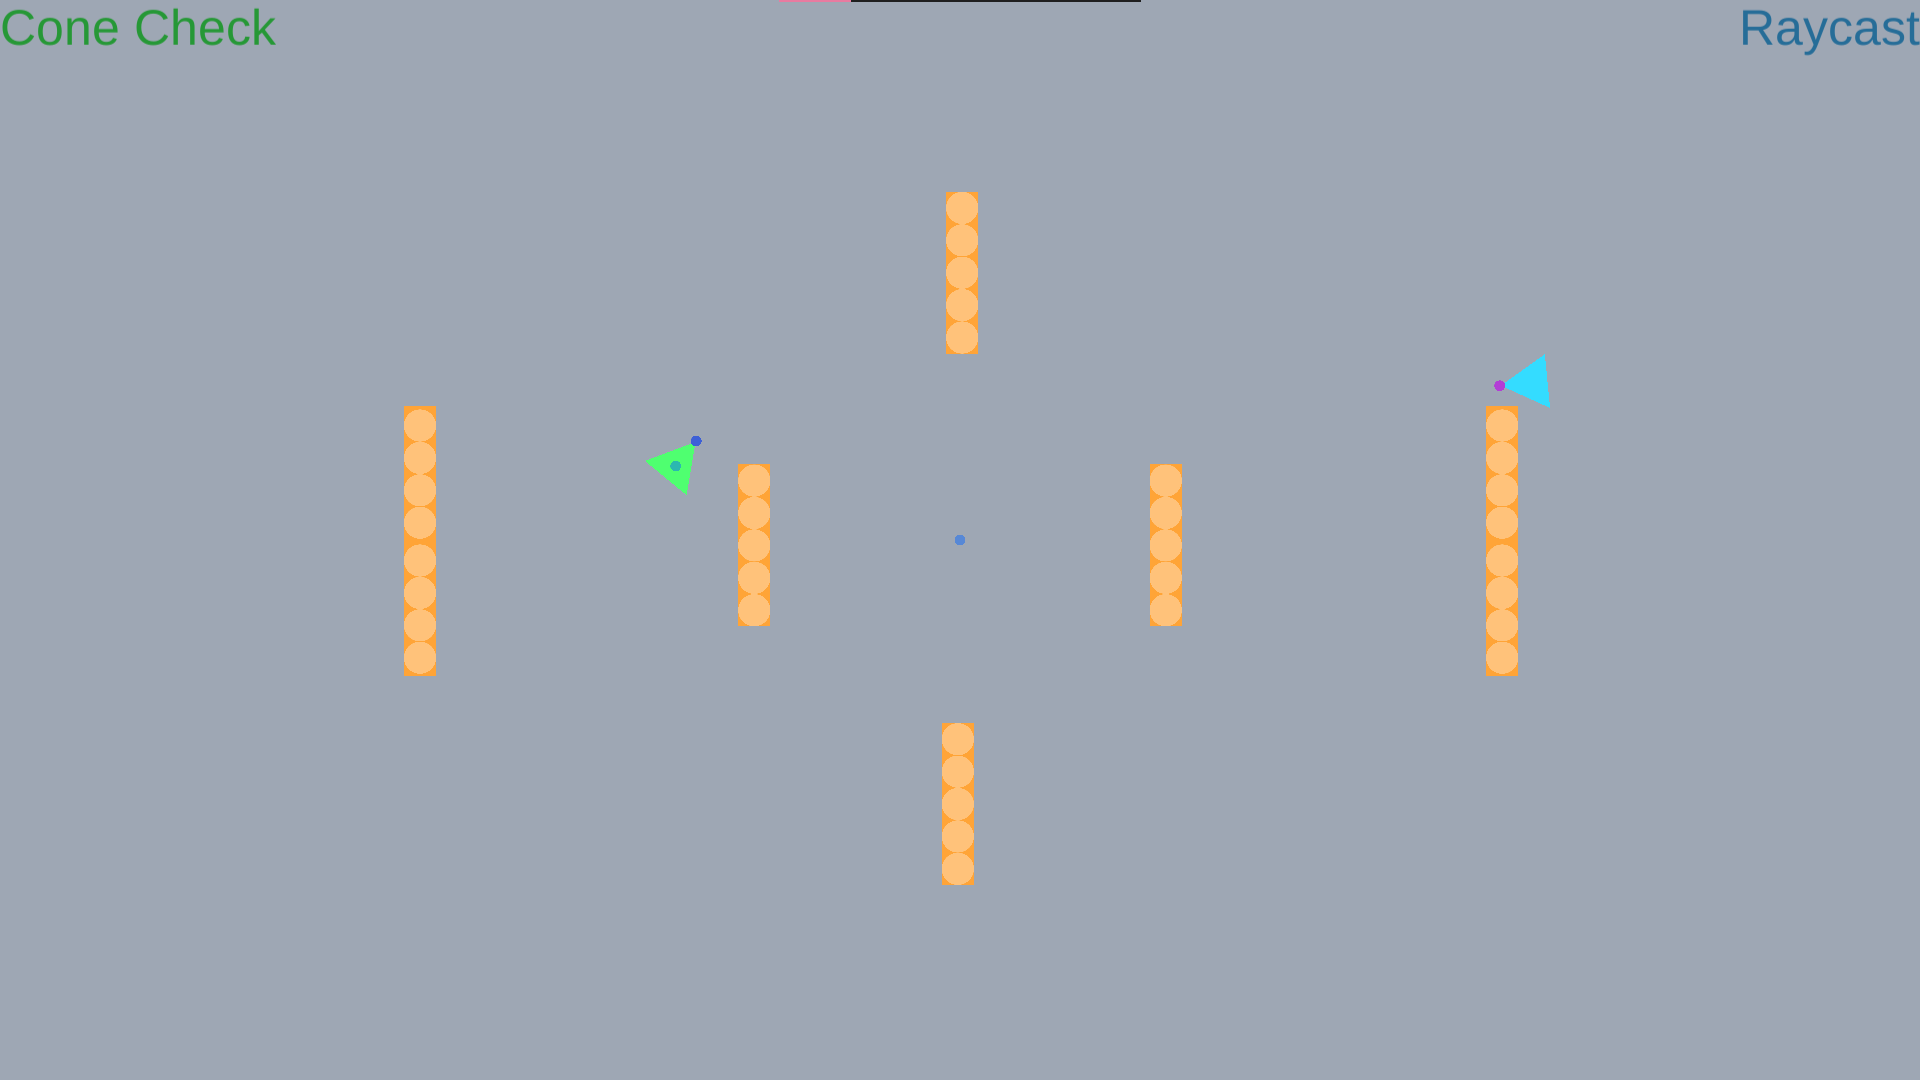
Implemented movement agents based on the paper "Steering Behaviors For Autonomous Characters" by Craig Reynolds and added additional features such as boids. Agent movement modes include predictive pursue, evade, path follow, and flocking (boids). Obstacle avoidance modes include raycast, cone check, and collision prediction. Features include dynamic obstacle avoidance modes (avoidance mode chosen based on situation, saves computation and gives better results), dynamic (acceleration-based) movement, player movement, and the ability for agents to pursue any transform. (Click the image to play some demos!)
Lorem ipsum dolor sit amet consectetur adipisicing elit. Optio amet dignissimos quidem, voluptatum incidunt eum!